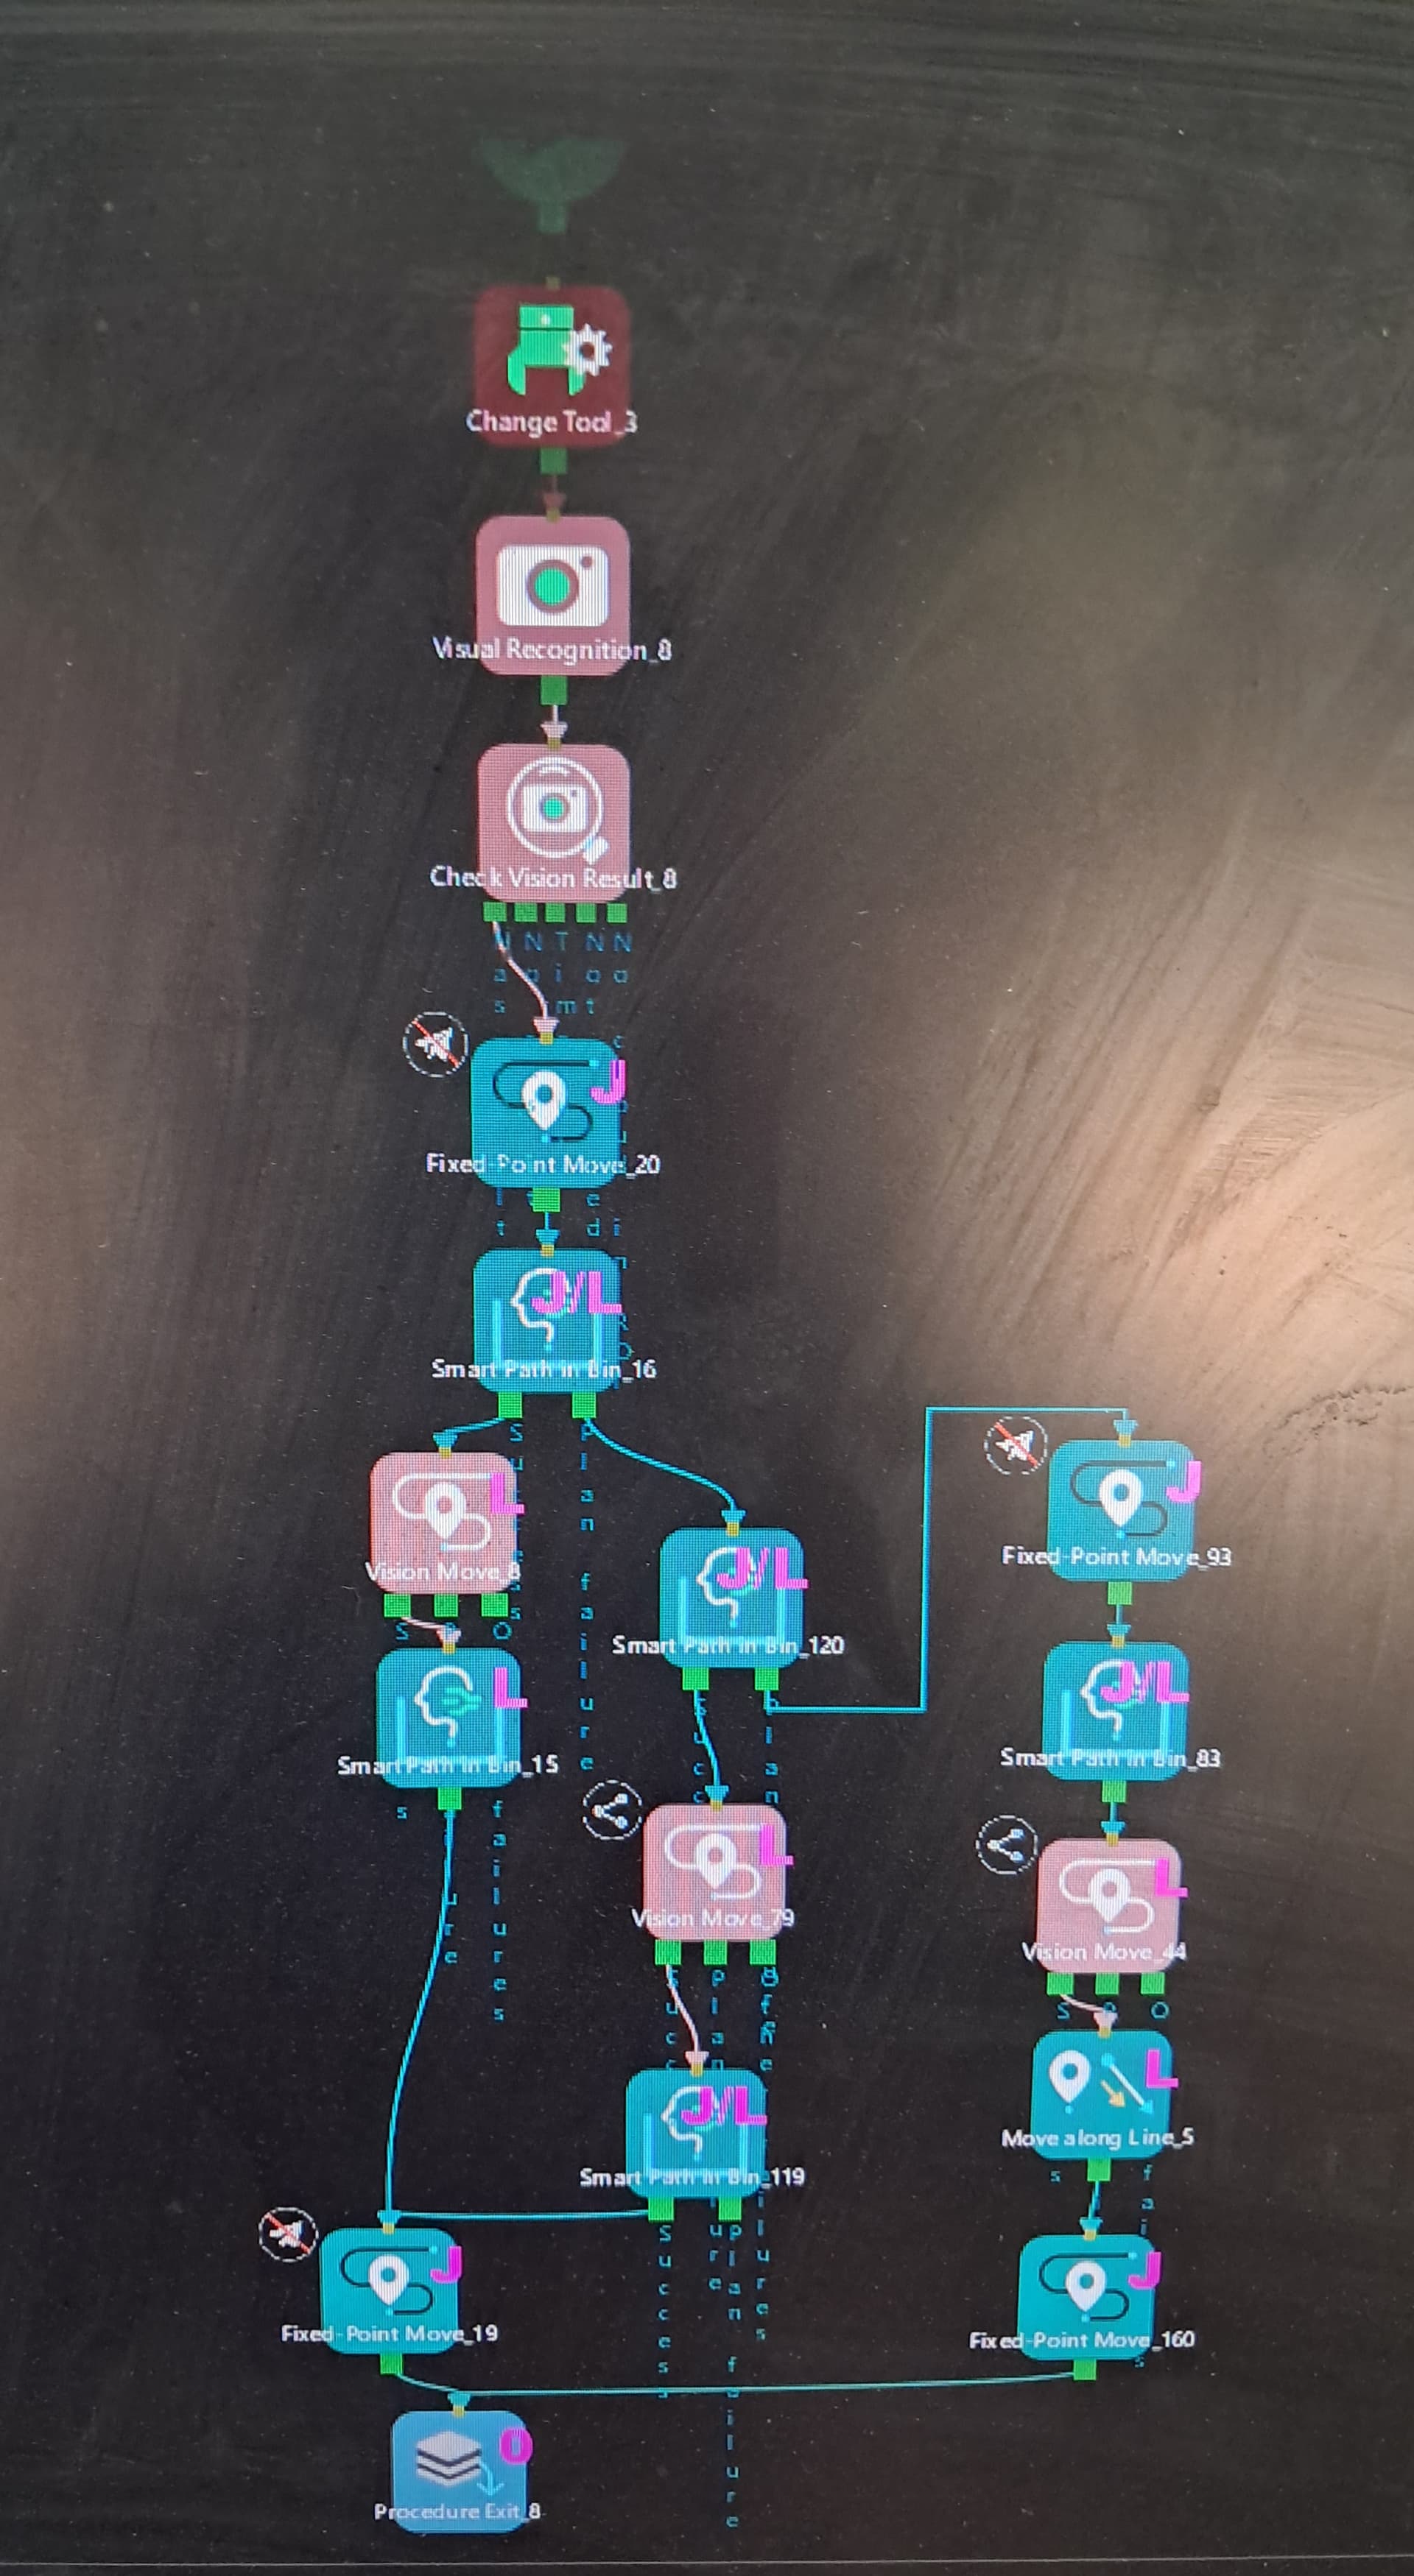
Good afternoon! I have a question regarding the detection of bin walls for a bin-picking task (using version 2.1.2). I would like to use the “Detect Bin (Two sides)” block. Could you please explain how to configure this block in “Mech-Vision” using my project as an example?
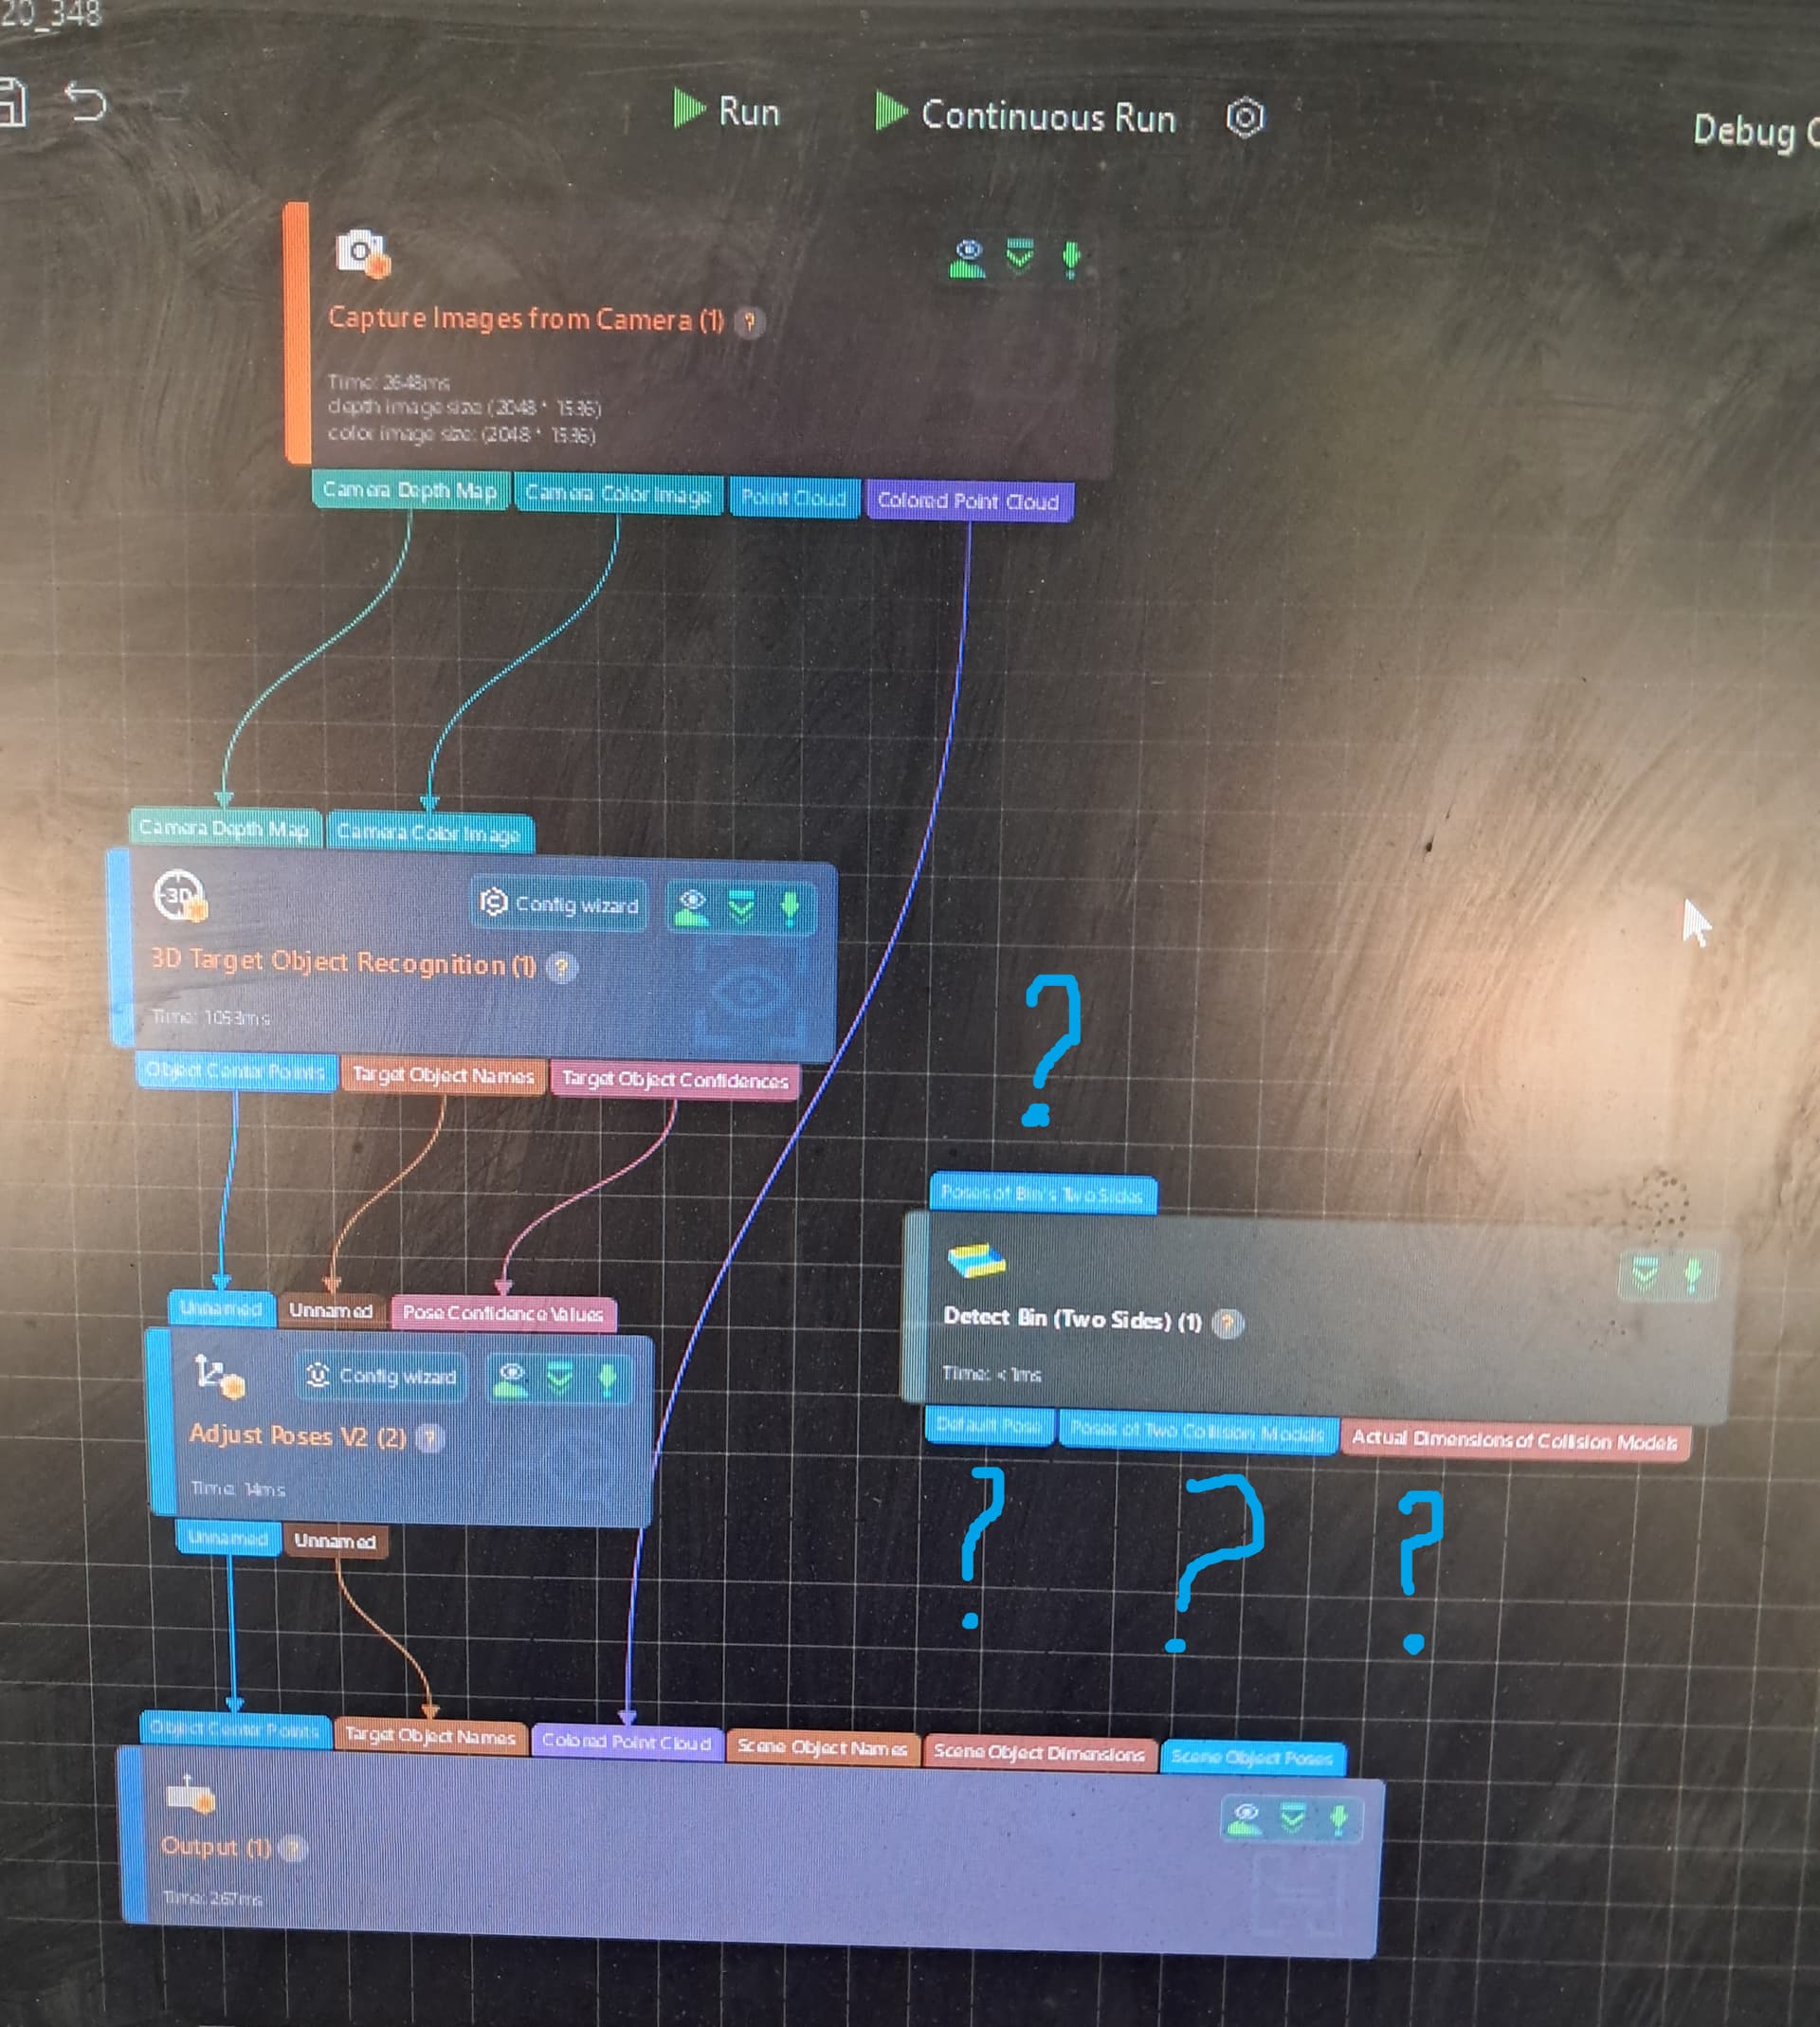
I have already entered the dimensions for the bin walls. I need to understand how to set up the detection for two sides, what should be connected to the “Poses of Bin Two Sides” input, and what should be connected to the “Default Pose,” “Poses of Two Collision Models,” and “Actual Dimensions of Collision Models” outputs. Could you please provide an image showing how to make these connections based on my project?
Also, are any changes required in “Mech-Viz” after adding this block in “Mech-Vision”?